前言
初步说明:
以下所有陈述都是关于描述数字硬件电路的。验证是另一个有趣的话题。
为了简洁,我们假设SystemVerilog是Verilog的最新版本。
当我们阅读这段话时,我们不应低估最喜欢的硬件描述语言对我们判断的影响。
为什么要放弃传统的 HDL
VHDL/Verilog 不是硬件描述语言
这些语言最初是为了模拟/文档目的而创建的事件驱动语言。只有在后来,它们才被用作综合工具的输入语言。这就解释了以下许多观点的根源。
事件驱动范式对于 RTL 没有任何意义
仔细想想,使用 process/always 块描述数字硬件 (RTL) 没有任何实际意义。为什么我们必须担心敏感列表?为什么我们必须在不同性质的进程(process)/always块之间分割我们的设计(组合逻辑/不带复位的寄存器/带异步复位的寄存器)?
例如,要实现这个:
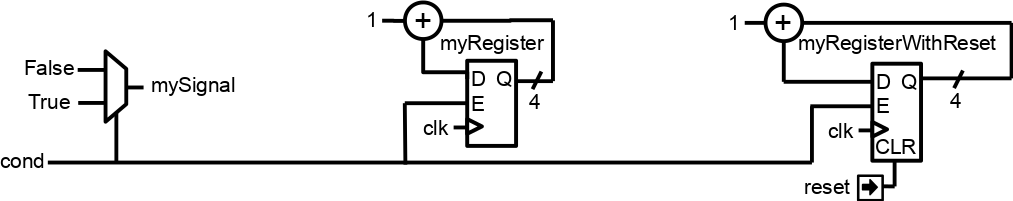
使用 VHDL 流程,您可以编写以下内容:
signal mySignal : std_logic;
signal myRegister : unsigned(3 downto 0);
signal myRegisterWithReset : unsigned(3 downto 0);

process(cond)
begin
    mySignal <= '0';
    if cond = '1' then
        mySignal <= '1';
    end if;
end process;

process(clk)
begin
    if rising_edge(clk) then
        if cond = '1' then
            myRegister <= myRegister + 1;
        end if;
    end if;
end process;

process(clk,reset)
begin
    if reset = '1' then
        myRegisterWithReset <= 0;
    elsif rising_edge(clk) then
        if cond = '1' then
            myRegisterWithReset <= myRegisterWithReset + 1;
        end if;
    end if;
end process;
使用 SpinalHDL 你可以这样写:
val mySignal             = Bool()
val myRegister           = Reg(UInt(4 bits))
val myRegisterWithReset  = Reg(UInt(4 bits)) init(0)

mySignal := False
when(cond) {
    mySignal            := True
    myRegister          := myRegister + 1
    myRegisterWithReset := myRegisterWithReset + 1
}
所有事情都是这样,您可以习惯这种事件驱动的语义,直到您尝试更好的事物。
VHDL 和 Verilog 的最新版本不可用
EDA 行业在其工具中实现 VHDL 2008 和 SystemVerilog 综合功能的速度确实很慢。此外,当它完成时,似乎只实现了该语言的一个约束子集(不谈论仿真功能)。结果是使用这些语言修订版的任何有趣功能都不安全,因为:
它可能会使您的代码与许多 EDA 工具不兼容。
其他公司可能不会接受您的 IP,因为他们的流程尚未准备好。
无论如何,这些修订并没有改变 HDL 问题的核心:它们基于事件驱动范的范式,这对于描述数字硬件没有意义。
VHDL 结构记录(record),Verilog 结构(struct)已经破碎(SystemVerilog 在这方面很好,如果您可以使用它)
You can't use them to define an interface, because you can't define their internal signal directions. Even worse, you can't give them construction parameters! So, define your RGB record/struct once, and hope you never have to use it with bigger/smaller color channels...
VHDL 的另一个奇特之处是,如果您想将某个数组添加到组件实体中,则必须将该数组的类型定义到包中...这就不能参数化了...
例如,下面是 SpinalHDL APB3 总线定义:
// Class which can be instantiated to represent a given APB3 configuration
case class Apb3Config(
  addressWidth  : Int,
  dataWidth     : Int,
  selWidth      : Int     = 1,
  useSlaveError : Boolean = true
)

// Class which can be instantiated to represent a given hardware APB3 bus
case class Apb3(config: Apb3Config) extends Bundle with IMasterSlave {
  val PADDR      = UInt(config.addressWidth bits)
  val PSEL       = Bits(config.selWidth bits)
  val PENABLE    = Bool()
  val PREADY     = Bool()
  val PWRITE     = Bool()
  val PWDATA     = Bits(config.dataWidth bits)
  val PRDATA     = Bits(config.dataWidth bits)
  val PSLVERROR  = if(config.useSlaveError) Bool() else null  // Optional signal

  // Can be used to setup a given APB3 bus into a master interface of the host component
  // `asSlave` is automatically implemented by symmetry
  override def asMaster(): Unit = {
    out(PADDR, PSEL, PENABLE, PWRITE, PWDATA)
    in(PREADY, PRDATA)
    if(config.useSlaveError) in(PSLVERROR)
  }
}
然后VHDL 2008有部分的解决方案和SystemVerilog接口/modport也能有所帮助,如果您的EDA工具/公司流程/公司政策允许您使用它们,那么您很幸运。
VHDL 和 Verilog 太冗长了
对于VHDL和Verilog,当它开始涉及组件实例化互连时,必须使用Ctrl-V/C大法。
要更深入地理解它,下面是一个使用SpinalHDL实例化一些外设并添加用于访问它们所需的APB3解码器的示例。
// Instantiate an AXI4 to APB3 bridge
val apbBridge = Axi4ToApb3Bridge(
  addressWidth = 20,
  dataWidth    = 32,
  idWidth      = 4
)

// Instantiate some APB3 peripherals
val gpioACtrl = Apb3Gpio(gpioWidth = 32)
val gpioBCtrl = Apb3Gpio(gpioWidth = 32)
val timerCtrl = PinsecTimerCtrl()
val uartCtrl = Apb3UartCtrl(uartCtrlConfig)
val vgaCtrl = Axi4VgaCtrl(vgaCtrlConfig)

// Instantiate an APB3 decoder
// - Driven by the apbBridge
// - Map each peripheral in a memory region
val apbDecoder = Apb3Decoder(
  master = apbBridge.io.apb,
  slaves = List(
    gpioACtrl.io.apb -> (0x00000, 4 KiB),
    gpioBCtrl.io.apb -> (0x01000, 4 KiB),
    uartCtrl.io.apb  -> (0x10000, 4 KiB),
    timerCtrl.io.apb -> (0x20000, 4 KiB),
    vgaCtrl.io.apb   -> (0x30000, 4 KiB)
  )
)
完成。这就是所有内容。在实例化模块/组件时,你不必一个接一个地绑定信号,因为你可以以面向对象的方式访问它们的接口。
另外,关于 VHDL/Verilog 结构/记录,可以说它们确实是无用的,没有真正的参数化和可重用性功能,仅仅是试图掩盖这些语言设计不佳的事实。
元硬件描述能力
VHDL 和 Verilog 提供了一些实例细化工具,这些工具不会直接映射到硬件中,如循环/生成语句/宏/函数/过程/任务。但仅此而已。
即便如此,它们的作用也确实有限。例如,不能将进程/always块/组件/模块块定义到任务/过程中。这确实是许多高级功能的瓶颈。
使用 SpinalHDL,您可以在总线上调用用户定义的任务/过程,如下所示:myHandshakeBus.queue(depth=64)。下面是一些包含定义的代码。
// Define the concept of handshake bus
class Stream[T <: Data](dataType:  T) extends Bundle {
  val valid   = Bool()
  val ready   = Bool()
  val payload = cloneOf(dataType)

  // Define an operator to connect the left operand (this) to the right operand (that)
  def >>(that: Stream[T]): Unit = {
    that.valid := this.valid
    this.ready := that.ready
    that.payload := this.payload
  }

  // Return a Stream connected to this via a FIFO of depth elements
  def queue(depth: Int): Stream[T] = {
    val fifo = new StreamFifo(dataType, depth)
    this >> fifo.io.push
    return fifo.io.pop
  }
}
让我们进一步想象,假设你想定义一个有限状态机。使用VHDL/Verilog,你需要编写大量原始代码,并使用一些switch语句来实现它。你不能定义"StateMachine"的概念,这将为你提供一个很好的语法来定义每个状态。否则,你可以使用第三方工具来绘制你的有限状态机,然后生成等价的VHDL/Verilog代码...
SpinalHDL 的元硬件描述能力使您能够定义自己的工具,然后允许您以抽象方式定义事物,例如有限状态机。
下面是SpinalHDL上有限状态机的一个简单的用法示例:
// Define a new state machine
val fsm = new StateMachine {
  // Define all states
  val stateA, stateB, stateC = new State

  // Set the entry point
  setEntry(stateA)

  // Define a register used into the state machine
  val counter = Reg(UInt(8 bits)) init (0)

  // Define the state machine behavior for each state
  stateA.whenIsActive (goto(stateB))

  stateB.onEntry(counter := 0)
  stateB.onExit(io.result := True)
  stateB.whenIsActive {
    counter := counter + 1
    when(counter === 4) {
      goto(stateC)
    }
  }

  stateC.whenIsActive(goto(stateA))
}
假设你想生成CPU的指令解码逻辑。这可能需要一些复杂的实例细化时算法来生成尽可能少的逻辑。但是,在VHDL/Verilog中,你唯一的选择是用脚本生成你想要的 .vhd 和 .v 文件。
关于元硬件描述确实有很多话要说,但理解它并得其真味的唯一方法就是进行实验。它的目标是停止直接使用电线和门,与那些抽象层级较低的东西保持一定的距离,并思考可重用的方法。